Design of Capsule-Shaped All-Terrain Robot: A Perpendicular Track Mobility Solution
2024 · IEEE · Vinay Murali, Pragna R, Annis Fathima, Abhishek Sebastian
A capsule robot with perpendicular dual tracks, PID tilt correction, and autoencoder anomaly detection for rough terrain.
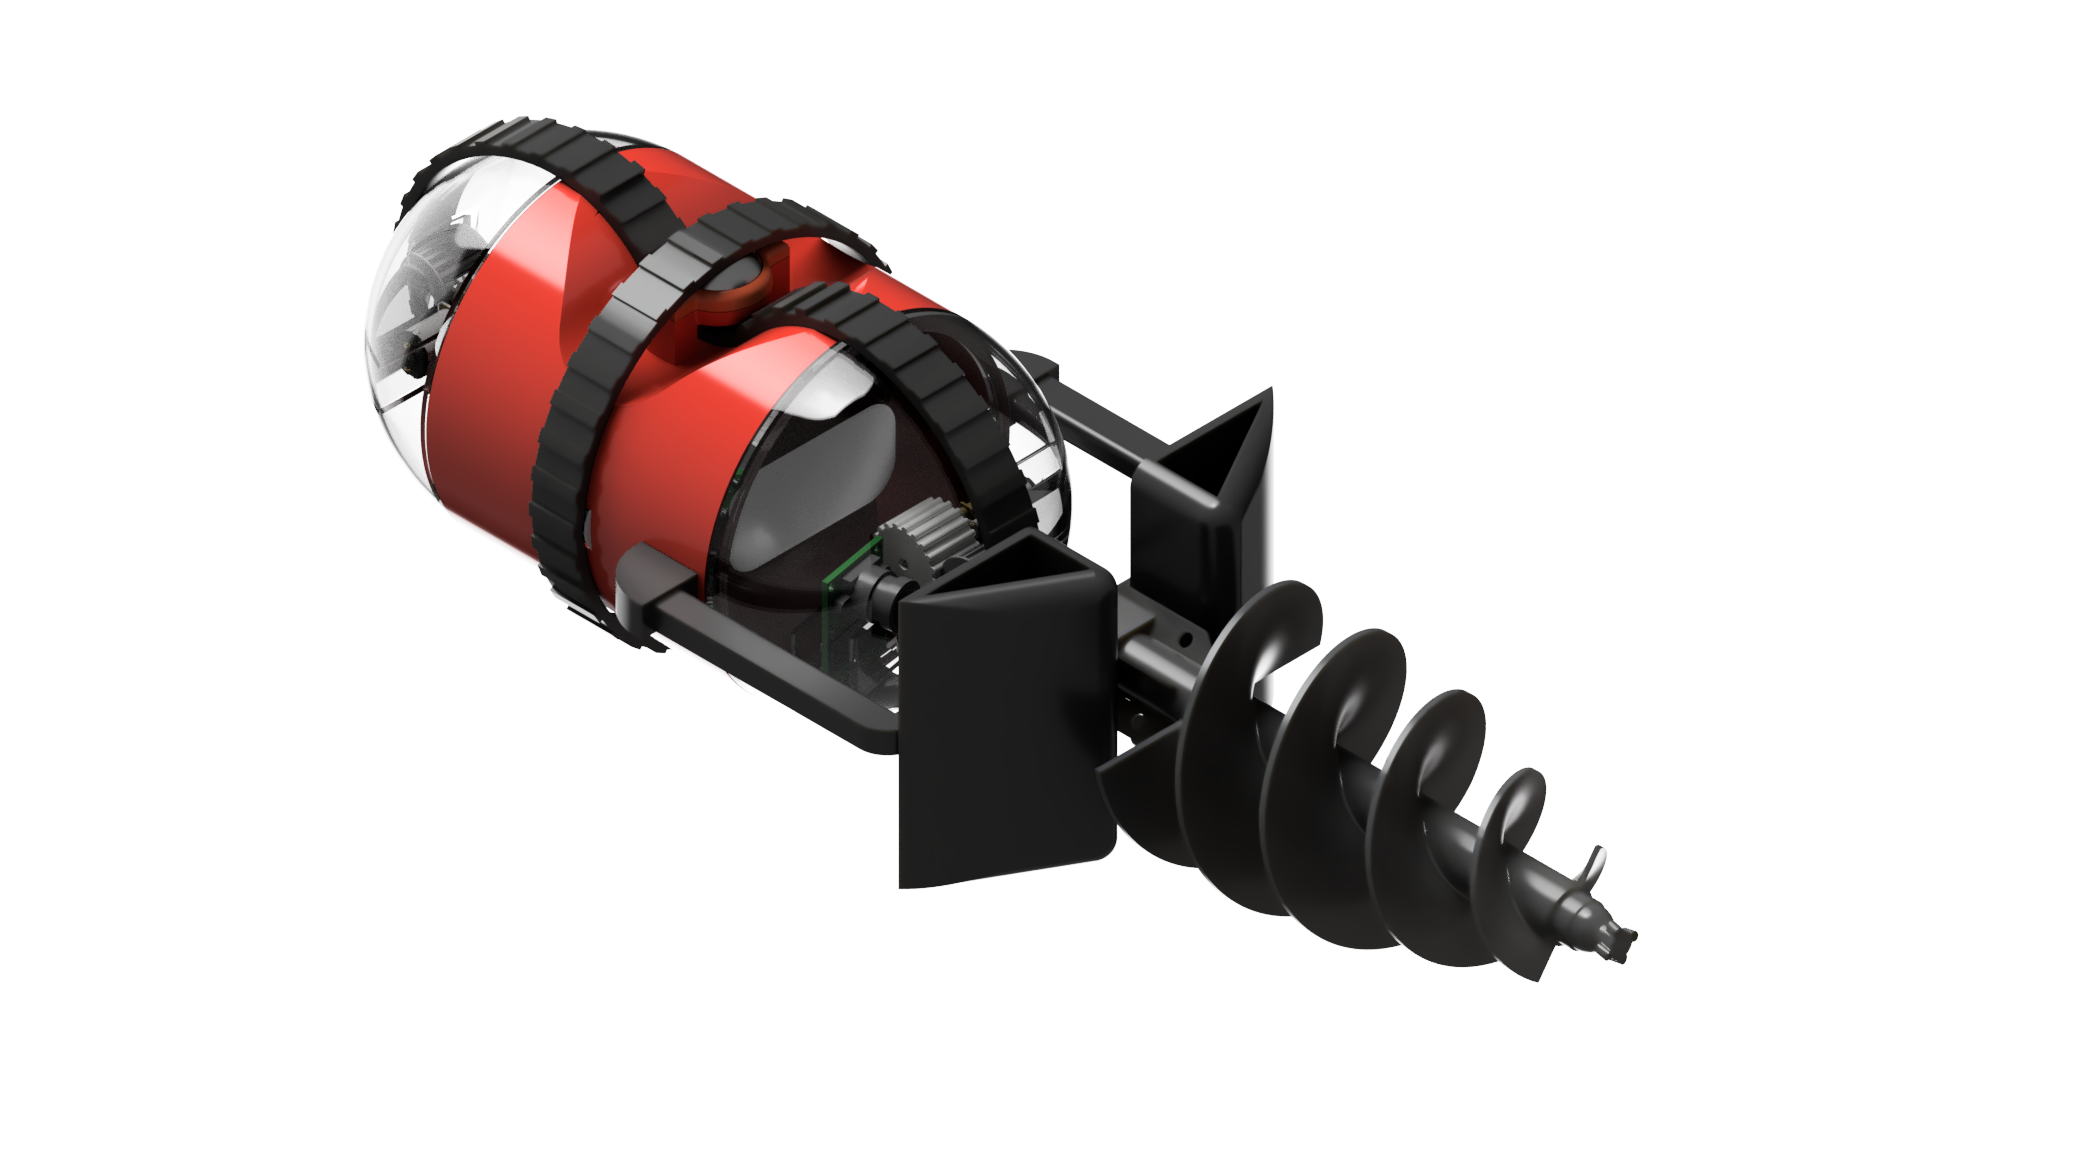
The Capsule Shape All-Terrain Robot (CS-ATR) targets disaster and landslide environments where stability and confined-space mobility matter. A perpendicular dual-track drive enables precise lateral motion; a real-time PID controller corrects tilt; and a variational autoencoder flags abnormal movement from sensor streams.
The study combines Simscape evaluation with prototype tests on sand, stones, and simulated pits. A prepared 10.28 m mobility course, including lateral motion and a 5-inch pipe, was completed in a reported 35.06 seconds.
The difficult surfaces are part of the finding: small stone pellets exposed slippage and reduced traction. The work connects a mechanical idea to control and testing, while leaving real disaster-site performance as a separate validation task.
Sense the tilt. Change the motion.
The robot’s sensing and camera feed give the controller and operator information about its surroundings and orientation.
Control-loop illustration. This is not a live robot controller or a terrain simulation.
- Robotics
- PID
- VAE
- Disaster response