System to Control and Navigate a Robotic Device in Landslide Impacted Terrains
Filed · Intellectual property
Remote console + ML anomaly pipeline for capsule robots in landslide zones.
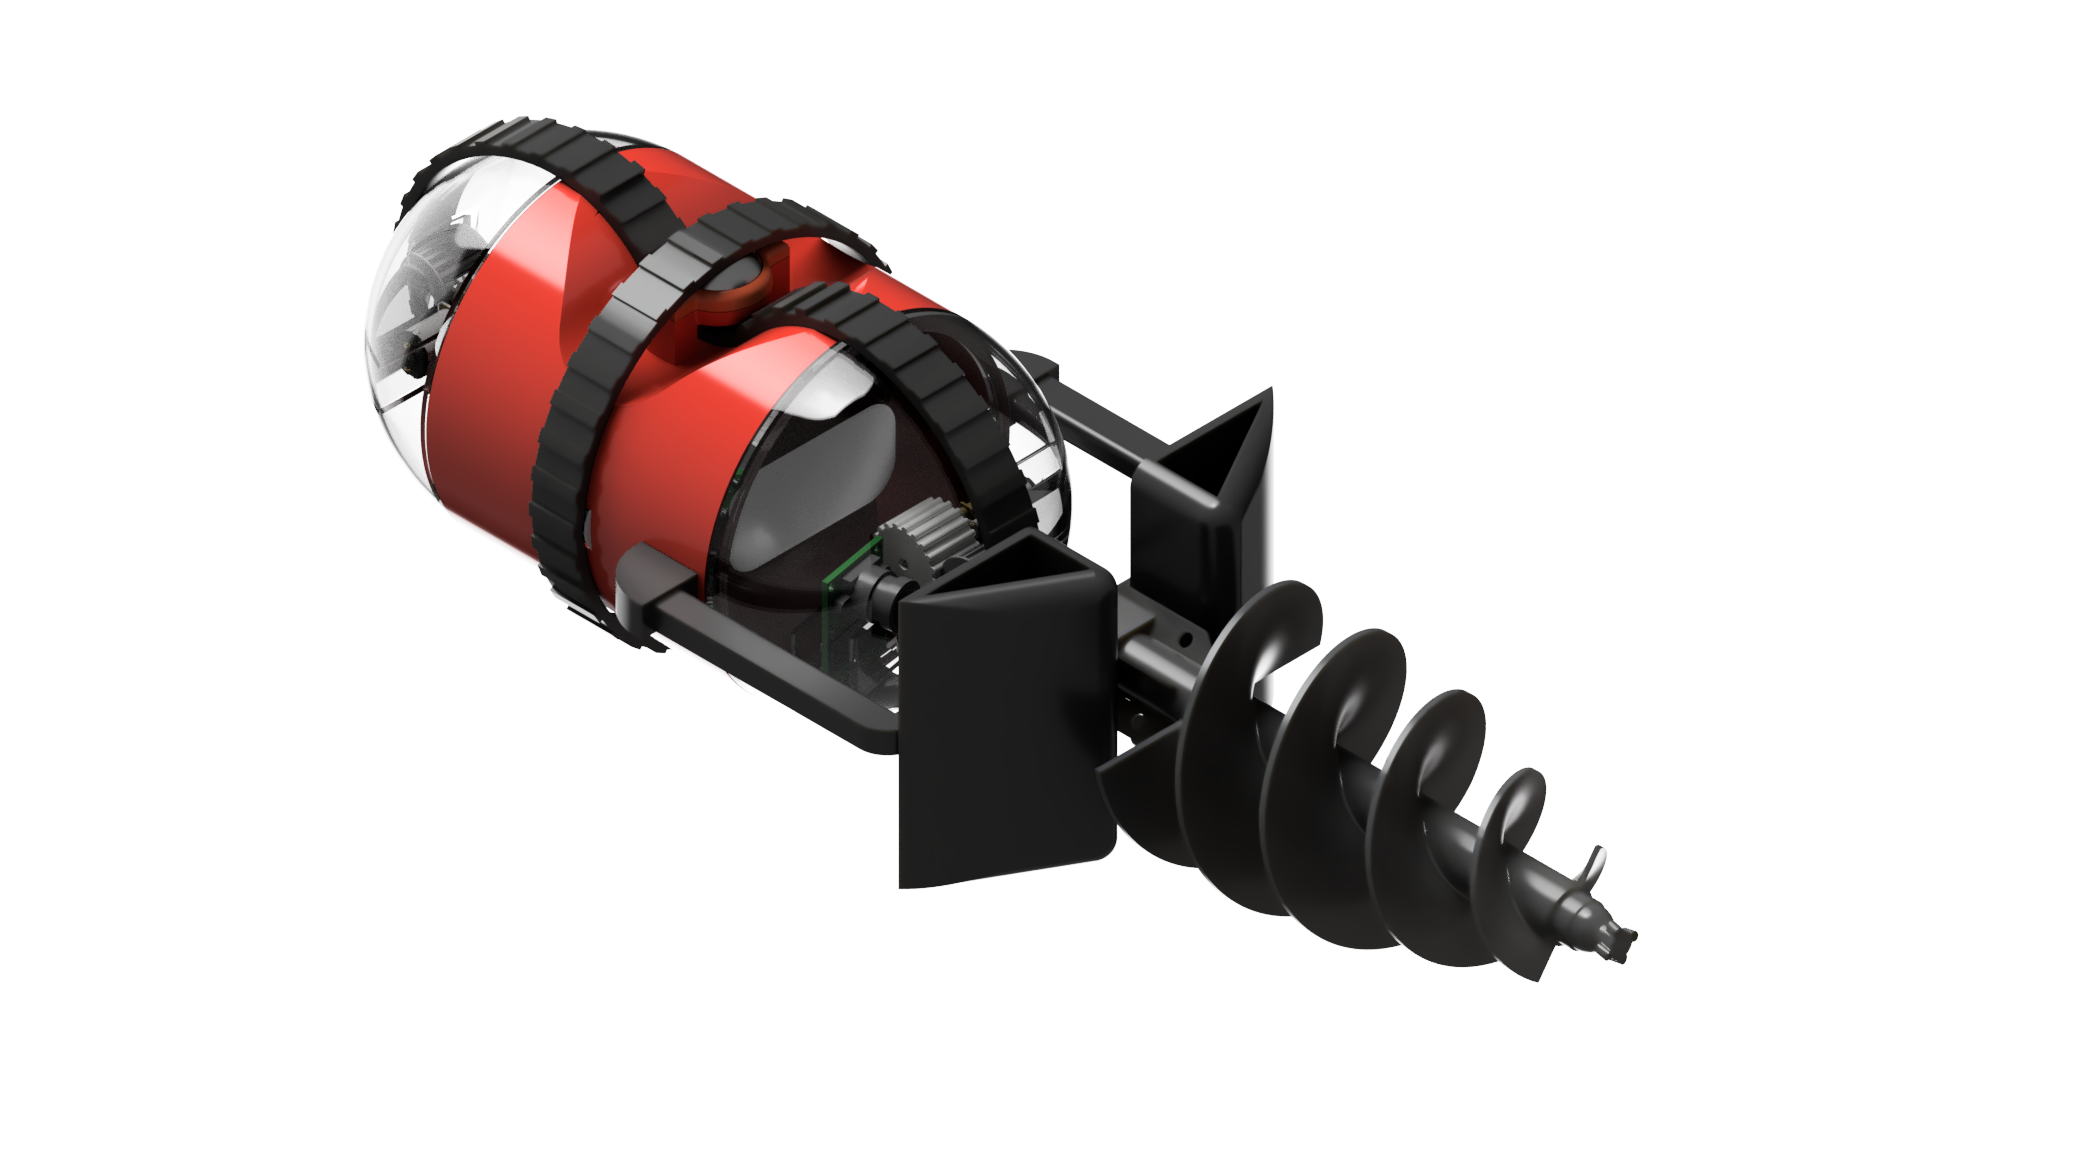
A capsule robot with camera sensors, accelerometer, and dual-track mobility connects to a computing unit and operator console. The stack analyses live imagery and orientation, runs ML anomaly detection, and feeds processed datasets back for manual control.
Control signals correct tilt and balance in real time — the filed utility companion to the CS-ATR research platform for landslide rescue.
The related paper makes the control problem tangible through perpendicular-track mobility, simulations, and prepared-terrain tests. The operator remains part of the proposed system; the application should not be read as evidence of fully autonomous rescue deployment.
Sense the tilt. Change the motion.
The robot’s sensing and camera feed give the controller and operator information about its surroundings and orientation.
Control-loop illustration. This is not a live robot controller or a terrain simulation.
Record 202541005588 · Status as recorded in the portfolio. Look up the current record at IP India ↗
Inventor’s project and patent descriptions ↗- Utility patent
- Robotics
- Disaster response